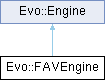
Fully Automatic Video Engine class. More...
#include <FAVEngine.hpp>
Public Member Functions | |
| virtual EvoRC | Init (const char *ccode, const char *dnnDevDesc, const char *url)=0 |
| virtual EvoRC | Init (const char *ccode, const char *dnnDevDesc, GIC::Dev::Ptr dev, uint32_t idxDS=0)=0 |
| virtual void | Deinit (void)=0 |
| virtual LPI::Ptr | PopLPI (GOP::Ptr &gop)=0 |
| virtual size_t | GetNumLPI (void) const =0 |
| virtual EvoRC | OpenLiveView (uintptr_t win, bool keepAR)=0 |
| virtual void | CloseLiveView (void)=0 |
| virtual EvoRC | SetColorOfSABL (const EvoColor &color)=0 |
| virtual EvoRC | SetDepthOfSABL (float depth)=0 |
| virtual EvoRC | DrawSABL (bool enable)=0 |
| Public Member Functions inherited from Evo::Engine | |
| virtual EvoRC | SetParam (EvoParam param, const void *value)=0 |
| virtual EvoRC | GetParam (EvoParam param, void *value) const =0 |
Static Public Member Functions | |
| static EVOFAVE_DECLSPEC Ptr | Create (void) |
Detailed Description
FAVEngine class provides funcionalities to detect and recognize all the license plates from video streaming whenever the automobile escape from the video area. Decoding the compressed video stream, this class uses H/W CODEC to reduce latency and CPU load. So, it is recommended to install the last display driver in that case. For details, refer to 'System Requirements' section.
Member Function Documentation
◆ CloseLiveView()
|
pure virtual |
The same as TSSEngine::CloseLiveView().
◆ Create()
|
static |
Create a engine instance.
- Returns
- Created engine instance. If fail, NULL returns. In that case, the error code can be obtained using GetLastRC().
◆ Deinit()
|
pure virtual |
Release all the resources in use. For further process, must be reinitialized.
- Note
- After called, recommend checking whether there is any LPI object in the output queue using GetNumLPI() or PopLPI() because any one could be queued while deinitializing.
◆ DrawSABL()
|
pure virtual |
Determine whether search area's boundary line is drawn on the live view window or not. To show it, the search area must be set and the live view window must be opened. Default is 'false'.
- Parameters
-
[in] enable Enable or disable drawing the boundary line
- Returns
- EvoRC code
- Note
- If all or either of the two conditions above is not met, this is automatically reset to 'false'.
◆ GetNumLPI()
|
pure virtual |
Get number of LPI objects which exist in the output queued.
- Returns
- Number of queued LPI objects
◆ Init() [1/2]
|
pure virtual |
Initialize the engine for video streaming based on IP protocol.
- Parameters
-
[in] ccode The same as SSEngine::Init(). [in] dnnDevDesc The same as SSEngine::Init(). If NULL, the engine builds optimal descriptor automatically. [in] url The same as TSSEngine::Init(const char*, const char*, const char*).
- Returns
- EvoRC code
- Note
- Don't use any white space in DNN Device Descriptor argument.
◆ Init() [2/2]
|
pure virtual |
Initialize the engine for video streaming from GenICam-compatable device.
- Parameters
-
[in] ccode The same as SSEngine::Init(). [in] dnnDevDesc The same as SSEngine::Init(). If NULL, the engine builds optimal descriptor automatically. [in] dev The same as TSSEngine::Init(const char*, const char*, GIC::Dev::Ptr, uint32_t). [in] idxDS The same as TSSEngine::Init(const char*, const char*, GIC::Dev::Ptr, uint32_t).
- Returns
- EvoRC code
- Note
- Don't use any white space in DNN Device Descriptor argument.
◆ OpenLiveView()
|
pure virtual |
The same as TSSEngine::OpenLiveView().
◆ PopLPI()
|
pure virtual |
Obtain LPI and GOP from output queue. If the queue is empty, this is blocked until there exist.
- Parameters
-
[out] gop GOP object related to the returned LPI. Before called, it must be NULL.
- Returns
- LPI object
- Note
- When error has occured, both of the LPI and GOP are NULL and the error code can be obtained using GetLastRC(). For example, if the video stream has been closed, GetLastRC() return 'EVORC_NO_MORE_DATA'.
◆ SetColorOfSABL()
Set the color of search area's boundary line on the live view window. Default is the solid red.
- Parameters
-
[in] color Color of the boundary line
- Returns
- EvoRC code
